arXiv · 2025 · Withdrawn preprint
SpikeGrasp: A Benchmark for 6-DoF Grasp Pose Detection from Stereo Spike Streams
SpikeGrasp infers 6-DoF robotic grasp poses directly from stereo spike streams via recurrent spiking networks without point-cloud reconstruction.
The scientific question
Can robots detect 6-DoF grasp poses directly from asynchronous spike streams?
Conventional robotic grasping relies on explicit 3D point-cloud reconstruction, a computationally heavy step absent from biological visuomotor pathways.
The core idea
Point-Cloud-Free Visuomotor Spiking Pipeline
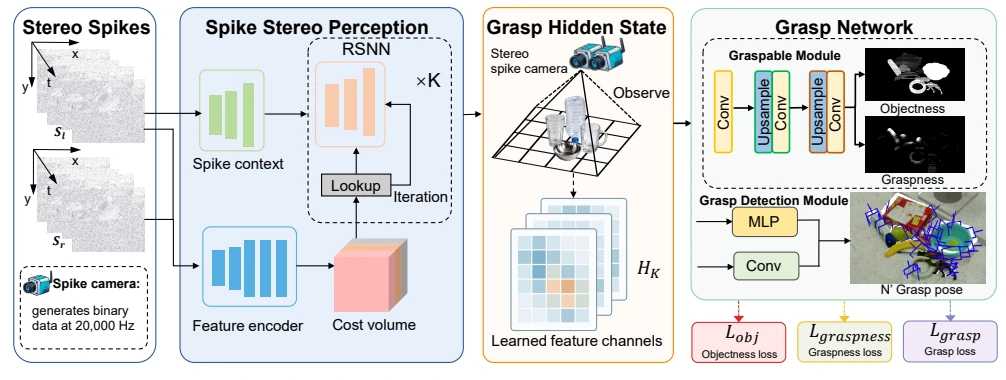
Mimicking biological visuomotor pathways, SpikeGrasp fuses binocular spike camera streams and uses a recurrent spiking network to iteratively refine 6-DoF grasp hypotheses end to end.
What we found
Data-Efficient Grasping in Clutter
Evaluated on a new large-scale synthetic stereo spike benchmark, SpikeGrasp outperforms point-cloud baselines in cluttered and textureless scenes with strong data efficiency.
The earlier arXiv preprint was withdrawn. The figure is from a different manuscript supplied by the author.
Continue the question
Related reading
- SpikeStereoNet: A Brain-Inspired Framework for Stereo Depth Estimation from Spike StreamsICLR 2026 · 2026
- SPKLIP: Aligning Spike Video Streams with Natural LanguagearXiv · 2025
Cite this work
Zhuoheng Gao, Jiyao Zhang, Zhiyong Xie, Hao Dong, Zhaofei Yu, Rongmei Chen, Guozhang Chen, Tiejun Huang. SpikeGrasp: A Benchmark for 6-DoF Grasp Pose Detection from Stereo Spike Streams. arXiv, 2025.